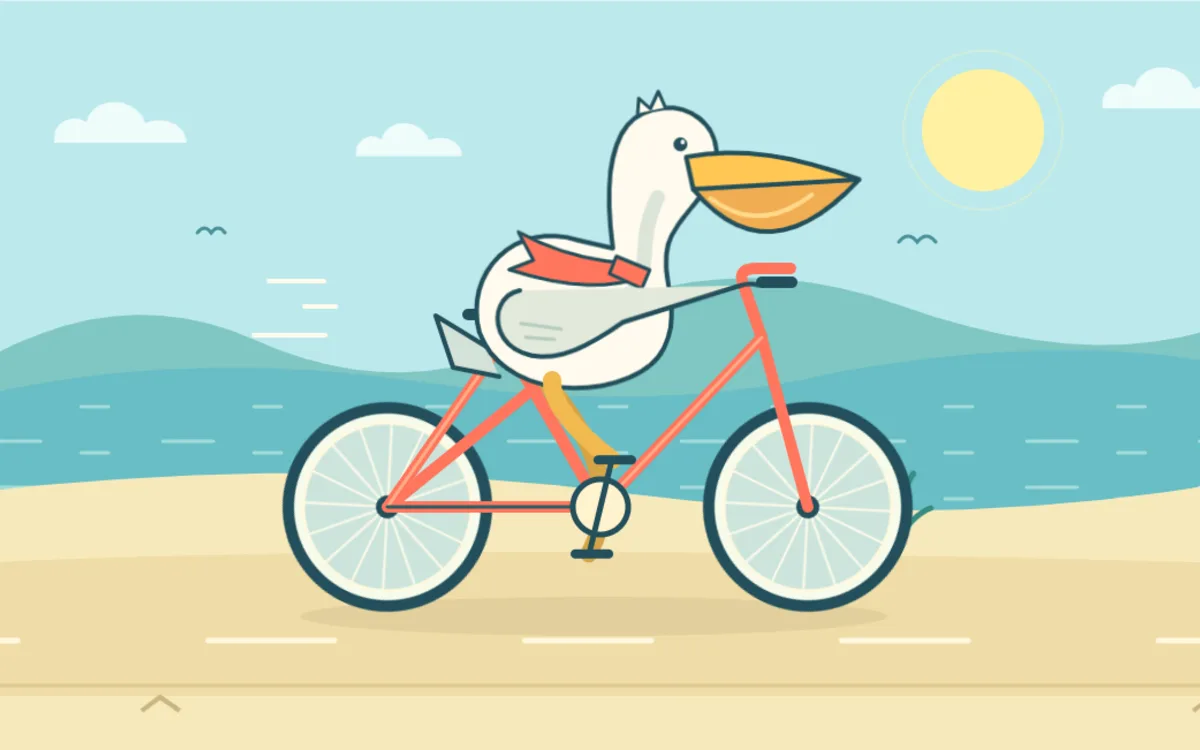
Loading runs…
This is the model's original HTML output. Its own controls are inside the frame.
Scorecard25 pts
Total
20.5 out of 25
Motion check
- Wheels rotate
- Yes
- Crank rotates
- Yes
- Feet track pedals
- Yes
- Scene moves
- Yes
Verdict
The cleanest art direction: cream paper, coral frame, and a poster-like header that reads “Today, tailwind.” Under the hood, the wheels spin and the legs are solved with inverse kinematics against a rotating crank, so the feet really do follow the pedals. The weakness is anatomy: the legs are thin curves with exaggerated knees, the feet are straight line segments, and the chain is missing. A pause button is included.
What works
- Correct inverse-kinematics foot tracking against a rotating crank.
- Wheels, crank, scarf, wing and road all move.
- Strong editorial layout and a working pause button.
What breaks
- Feet are 29px straight lines, not webbed pelican feet.
- Knees bend past the plausible range, producing a loop-like leg.
- No chain; the drivetrain is simplified.
Spec
- Vendor
- OpenAI
- Access
- Consumer client, zero-shot
- Tested
- 2026-10-27
- Controls
- Pause button
- File
- gpt-6-1-sol.html · 8.5 KB
- Rank
- 3 / 8
Editorial score, one run. The full rubric is in the methodology.