GPT-6.1 Terra
Beautiful sea light, but the feet kick circles around the hip instead of the crank.
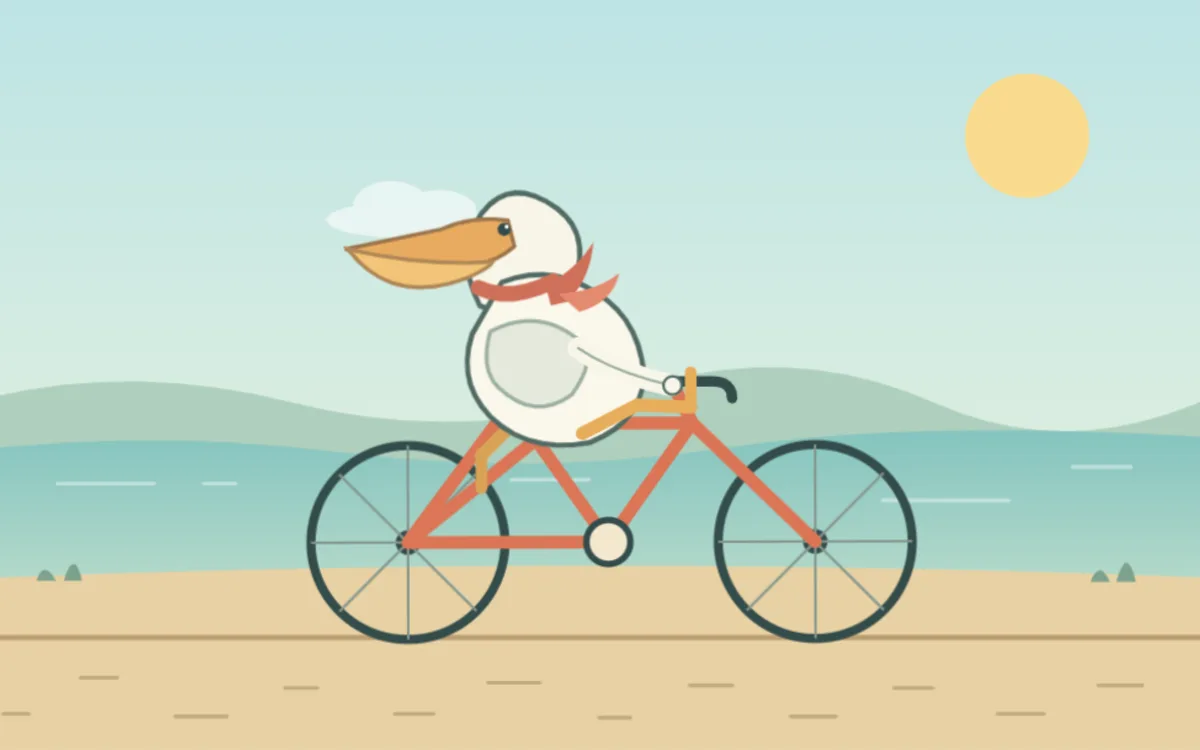
This is the model's original HTML output. Its own controls are inside the frame. This model shipped no playback controls. Use reload to watch it again.
Scorecard25 pts
Motion check
- Wheels rotate
- Yes
- Crank rotates
- No
- Feet track pedals
- No
- Scene moves
- Yes
Verdict
A seaside scene you could hang on a wall, over a bicycle that does not work. Measured over one 1.2 s cycle: both rims sweep a full 360° clockwise while the sand slides left, so the direction of travel is right, and the spokes change 7,657 of 24,964 pixels inside the rear wheel box and 7,658 inside the front — the wheels genuinely turn. Nothing below the saddle agrees. There is no crank and no pedal anywhere in the file: the bottom bracket is a solid cream disc, r = 17 at (505, 422). Both legs are hinged at the same point, the hip at (485, 338), so each foot orbits the body at radius 86; sampled across the cycle the feet sit between 24 and 164 units from the crank centre and rise to y ≈ 258, above the saddle line and in front of the torso, while `.leg-b` runs the identical circle in the opposite direction (`animation-direction: reverse`), so the two legs coincide twice per revolution and sit on opposite sides of the circle in between. The gearing is wrong too: the rim surface covers 393 units/s against a road stepping 80, a 4.9× slip — the bike is spinning its wheels rather than riding. The scene forgives a lot of that. Gradient sky and sea, a low sun, two cloud layers on 18 s and 25 s loops, grass tufts, a scarf, and a body bob whose 0.6 s alternate period lands exactly on one wheel revolution. The pelican looks backwards, and with zero JavaScript in the page the only pause is the one this site adds.
What works
- Both wheels genuinely turn: over one second the spokes change 7,657 of 24,964 pixels in the rear wheel box and 7,658 in the front, clockwise against a road that slides left.
- Contact mostly reads — the body's bounding box (bottom y ≈ 354) covers the saddle line at y = 311, the rims bottom out at y = 497 against a ground stroke at 493, and the wing ends in a small hand on the bar grip at (555, 301).
- Zero JavaScript, zero console errors, no overflow at 390 px — and the body bob's 0.6 s alternate period lands exactly on one wheel revolution.
What breaks
- No cranks, no pedals and no chain: the bottom bracket is a solid disc, so the feet have nothing to push.
- Both legs hinge from the hip at (485, 338) and orbit it at radius 86 — the feet stay 24–164 units from the crank centre, sweep up to y ≈ 258 across the torso, and run the same circle in opposite directions.
- The wheels are geared about 4.9× faster than the ground (393 units/s of rim against 80 units/s of road), the pelican looks backwards, and the road dashes repeat every 73–86 units while the loop steps exactly 80, so the sand jumps once a second.
Spec
- Vendor
- OpenAI
- Access
- Consumer client, zero-shot
- Tested
- 2026-10-31
- Controls
- None
- File
- gpt-6-1-terra.html · 5.6 KB
- Rank
- 9 / 12
Editorial score, one run. The full rubric is in the methodology.