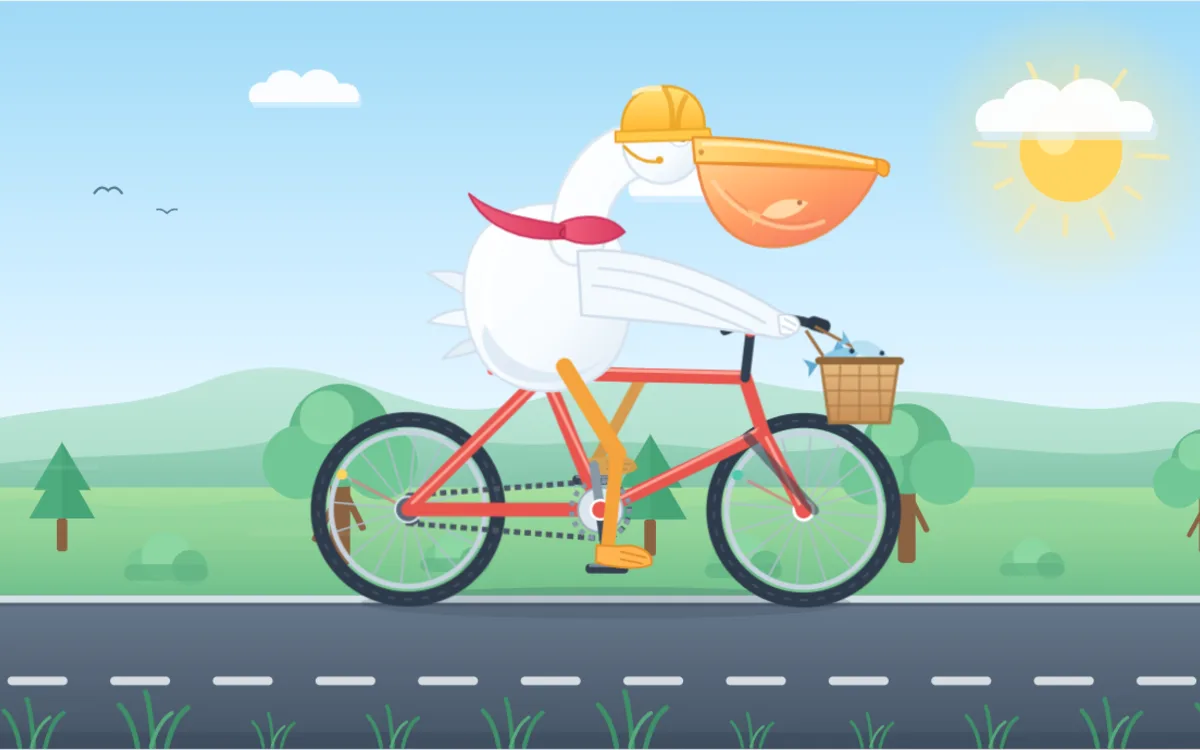
This is the model's original HTML output. Its own controls are inside the frame.
Scorecard25 pts
Motion check
- Wheels rotate
- Yes
- Crank rotates
- Yes
- Feet track pedals
- Yes
- Scene moves
- Yes
Verdict
HY4 writes the best legs in the test and then freezes the two surfaces that prove a bicycle is rolling. The solver is the textbook two-bone version in absolute units — `L1 = L2 = 95`, law of cosines, perpendicular offset kept in real units — and it holds: over 90 frames the near thigh measures 94.94–95.06 and the shin 94.92–95.09, and both feet sit at exactly 0.00 from their pedals, before and after pause. Everything else is declared rather than eyeballed: the road scrolls 209.1 units against 142.61° of wheel rotation, which implies an 84.01-unit tyre on an 84-unit drawing, and the crank turns at 0.3921 of wheel speed against the `GEAR = 2.55` in the constants. Bike and bird bob as one rig (−4.1 to +3.4 units, ±0.45° of pitch) and the contact shadow breathes with them. Then the tells. The tyre tread is a dashed circle sitting outside the spoke group, so the pattern never moves while the spokes do; the chain is a closed dashed outline with no `stroke-dashoffset` anywhere in the file, so it never runs; and the drivetrain that was drawn — chainring r 27 over cog r 12, a 2.25 ratio — contradicts the 2.55 being animated. The wing lies along the bar and stops 4–5 units short of the grip cap, the body covers the saddle completely, and at 390px the control panel wraps to four rows and lands on the title card and the HUD. It is still the only run here with a real control rig that survives inspection: pause, 2.2× boost, bell, a 0.3–2.2 slider, click-to-boost and five key bindings, all driven by one requestAnimationFrame loop with no CSS or SMIL to hide behind.
What works
- The correct two-bone IK in absolute units: 90 frames put the thigh at 94.94–95.06 and the shin at 94.92–95.09 against a declared 95/95, with both feet at distance 0.00 from their pedals before and after pause.
- Rolling derived instead of guessed: 209.1 units of road against 142.61° of wheel is an implied 84.01 radius on a tyre drawn at 84, and the crank turns at 0.3921 of wheel speed against the declared 1/2.55.
- The richest control panel on the board — pause (54 differing pixels across 1.4 s), 2.2× boost with a HUD that answers 11 → 24 km/h, a bell with a 0.85 s bubble, a 0.3–2.2 slider, click-the-stage boost and five keys — with zero console errors and one rAF loop running the whole scene.
What breaks
- The tyre tread is a dashed circle outside the rotating spoke group and the chain is a static dashed outline: there is no `stroke-dashoffset`, no `@keyframes` and no SMIL in the file, so the two surfaces that sell rolling never move.
- The drawn drivetrain argues with the animated one — chainring r 27 over cog r 12 is a 2.25 ratio, the chain path even arcs at 27 and 13 — while the code runs `GEAR = 2.55`.
- At 390×844 the absolutely positioned `.controls` panel wraps to four rows and covers the title card (12,993 px²) and the HUD (6,273 px²), the only overlay collision in this set; `prefers-reduced-motion` is ignored (the crank still turns 80.7° per second), the body hides the saddle completely, and the bell bubble is Chinese-only (叮叮!).
Spec
- Vendor
- Tencent Hunyuan
- Access
- Consumer client, zero-shot
- Tested
- 2026-11-05
- Controls
- Pause, boost, bell, speed slider, five keys
- File
- hy4.html · 36.7 KB
- Rank
- 3 / 13
Editorial score, one run. The full rubric is in the methodology.